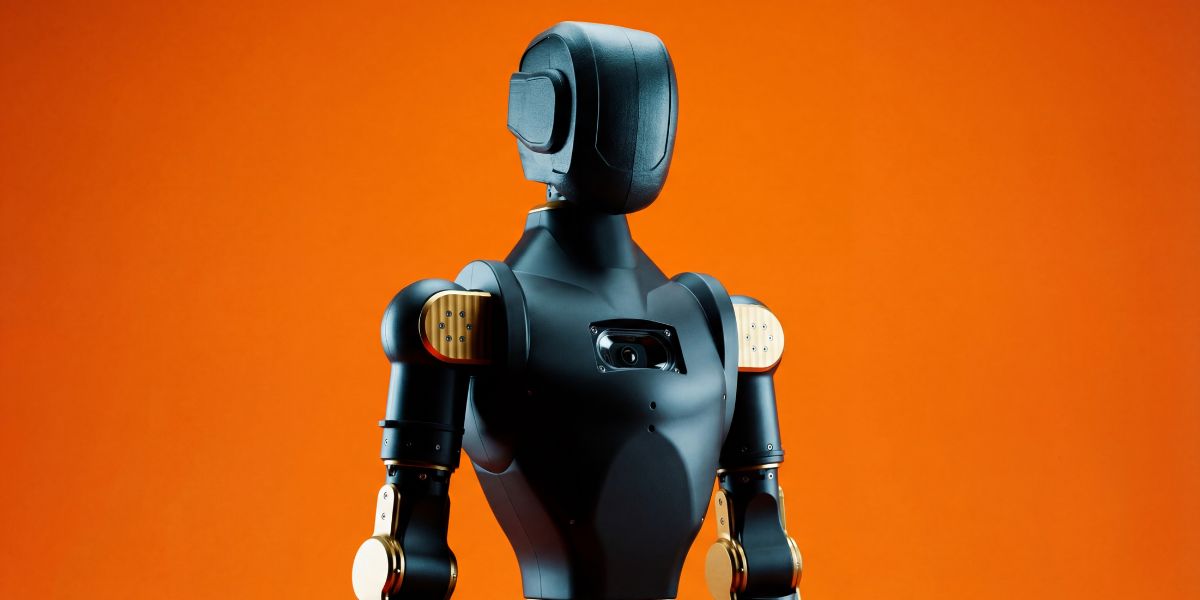
Asimov is an open-source humanoid robot that you can build, train and customize.
Asimov 1 is a 1.2 m, 35 kg biped with 25 actuated degrees of freedom. This repository contains the mechanical CAD, electrical CAD, simulation model, and onboard software to build, simulate, and customize Asimov 1.
| Spec | Value |
|---|---|
| Height | 1.2 m |
| Weight | 35 kg |
| Degrees of Freedom | 25 actuated |
| Legs | 6 DOF x 2 |
| Arms | 5 DOF x 2 (shoulder pitch/roll/yaw, elbow, wrist yaw) |
| Torso | 1 DOF waist yaw, 10 W 4 ohm speaker, 6 DOF IMU |
| Head | 2 DOF neck (neck yaw, neck pitch), stereo microphone array, 2MP monocular camera |
| CAN Bus | 5 @ 1Mbps + 1 @ 500kbps |
| Onboard Compute | Raspberry Pi 5 (media + network) + Radxa CM5 (motion control) |
| Structural Materials | 7075 aluminium, MJF PA12 nylon |
| Activity | Rated Load | Peak Load |
|---|---|---|
| Squat | 5 kg | – |
| Bicep curl | 5 kg each arm | 15 kg each arm |
| Front raise | 5 kg each arm | 15 kg each arm |
| Lateral raise | 6 kg each arm | 18 kg each arm |
Design file: https://github.com/menloresearch/asimov-1?fbclid=IwY2xjawT3MOFwZG9mBWV4dG4DYWVtAjEwAGJyaWQRMThTcE9EU2xBYWNzUW1sVVFzcnRjBmFwcF9pZBAyMjIwMzkxNzg4MjAwODkyAAEevseN70PI9M05g9-6M5x1qlLaRkZiIe-ZECmkJysQmkeeNgMVruRMaOnodIU_aem_kan53gmkNwL79TWUJzaTDg
Order Kaitech: “We offer precision machining and sheet-metal fabrication of robot frames and enclosures, along with component supply”

